Welcome to imperix knowledge base
This section aims to be a growing base of documentation and resources for all imperix software and products.
Applications (view all)
Applications contain articles aimed at the implementation of complete systems, often adapted to laboratory-scale power levels. The corresponding articles provide relevant technical details about one selected implementation.
Tutorials (view all)
Tutorials are made of several articles addressing a common topic or field of interest. The articles are ordered by increasing order of complexity, also corresponding to typical implementation steps during experimental activities.
User Manuals (view all)
User Manuals regroup articles specifically related to imperix products. They present useful information to get started with standard equipment and provide guidance on how to make the most of the imperix software environment.
Highlighted Articles


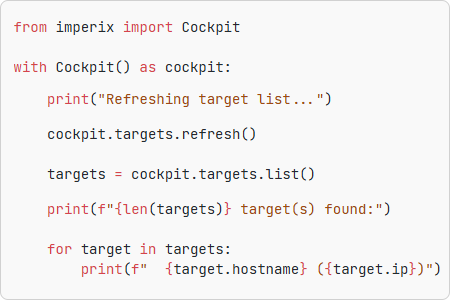
Getting started with Python scripting
Imperix Cockpit provides a graphical interface for managing real-time control software running on imperix controllers. It supports a wide range of actions, from testing transient...


Programming and operating imperix controllers
This document provides guidance for first-time users on the essential procedures for deploying code to imperix controllers and connecting to the equipment. It is applicable...


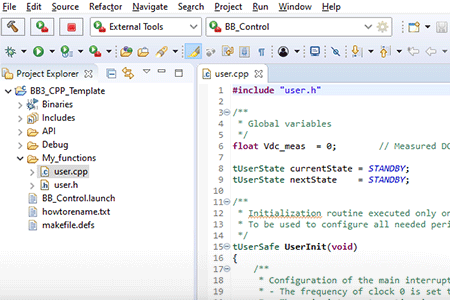
Installation guide for imperix CPP SDK
This page provides step-by-step instructions for installing the imperix CPP SDK. It also provides guidance for importing the user template into the Integrated Development Environment...
Recent Articles


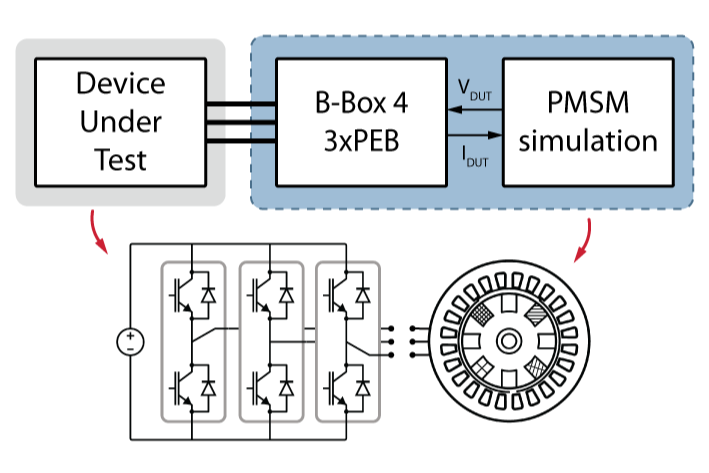
Motor emulation for PHIL prototyping
This article presents a Power Hardware-in-the-Loop (PHIL) system where the behavior of a Permanent Magnet Synchronous Machine (PMSM) is emulated for the validation of a...

Microgrid emulation for PHIL prototyping
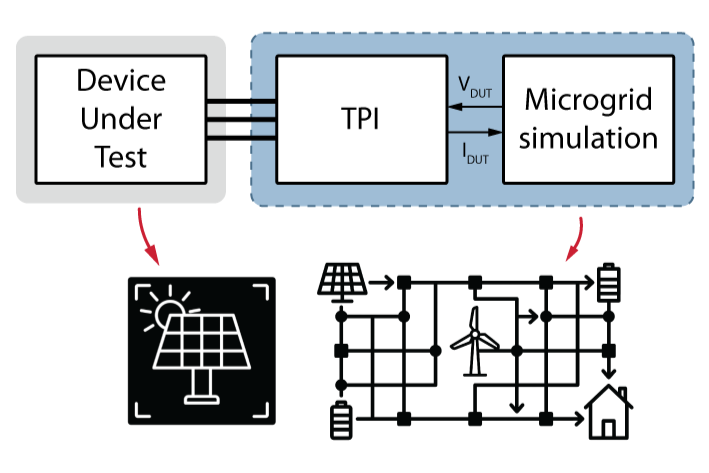
This article presents a Power Hardware-in-the-Loop (PHIL) application integrating imperix hardware with third-party simulators. In this example, the setup emulates a microgrid, and loads it...

PHIL prototyping with imperix hardware
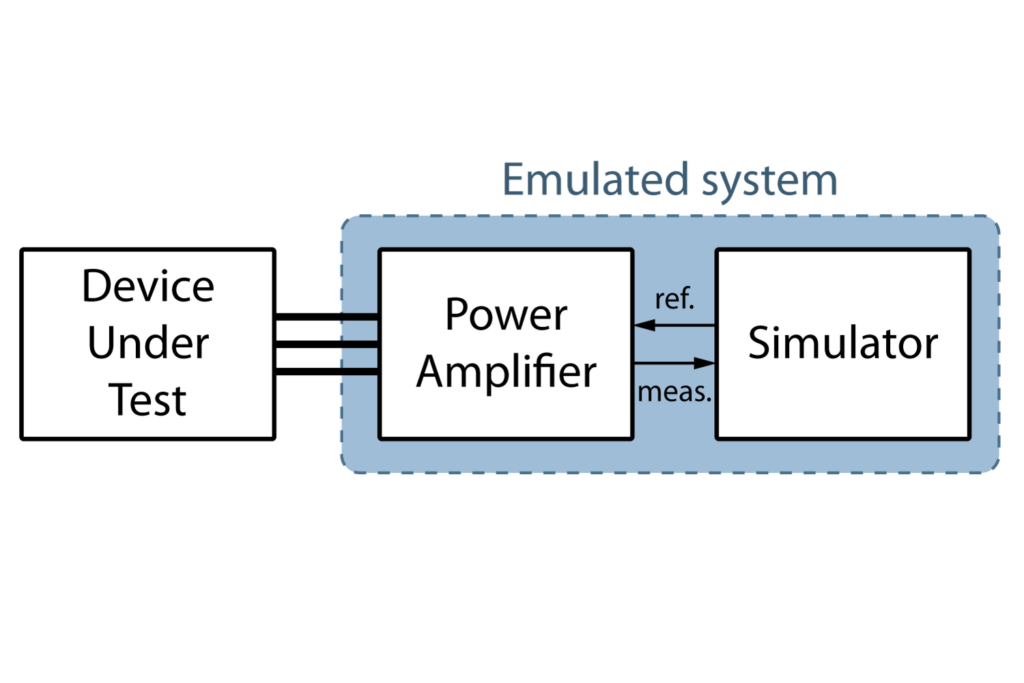
Power Hardware-In-the-Loop (PHIL) is a well-known method to validate the electrical behavior of a power device under test (DUT) under specific conditions without the need...

Software documentation
These notes provide documentation for all the blocks and functions packed with ACG SDK and CPP SDK. Each page covers the configuration parameters and the use of a specific peripheral block within the Simulink, PLECS, and C++ environment