Automated parameter sweep using Python
 PN205
This application note shows how to use Python scripting to automate actions otherwise performed manually in Cockpit. Doing so, it also introduces a recommended workflow…
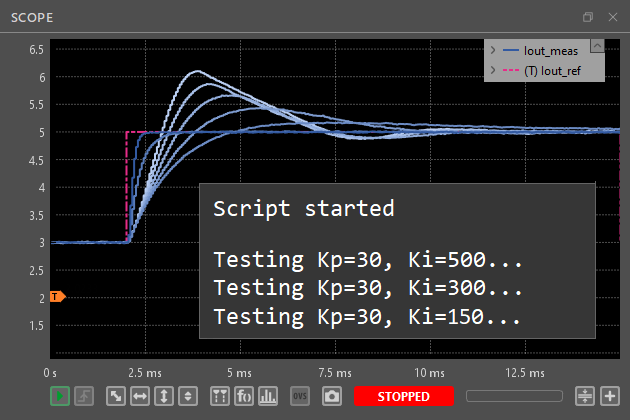
This application note shows how to use Python scripting to automate actions otherwise performed manually in Cockpit. Doing so, it also introduces a recommended workflow…
Imperix Cockpit provides a graphical interface for managing real-time control software running on imperix controllers. It supports a wide range of actions, from testing transient…
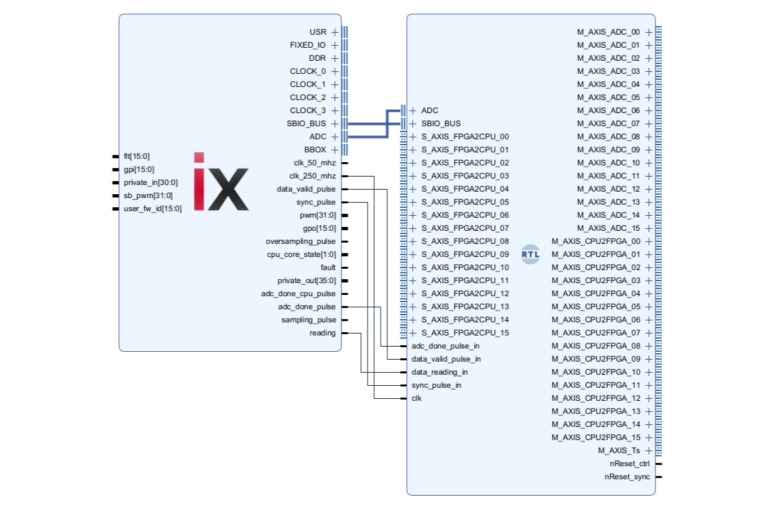
Imperix provides direct access to ADC measurements within the FPGA which allows for reduced delay between the sampling and the processing, but also helps supporting…
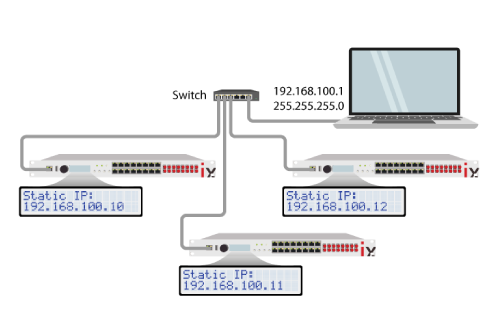
In most cases, connecting to the target using its dynamic IP address is straightforward and requires no additional setup. This dynamic IP is typically either…
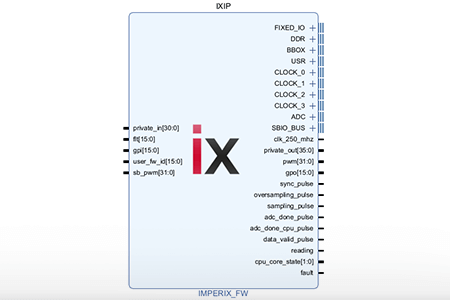
This page provides the imperix sources files required to start programming the FPGA on imperix controllers. The provided archive contains the imperix firmware IP and…
The B-Box RCP SD card contains the B-Box firmware (bitstream.bit.bin and linux.bin) and the license file (license.lic). Other optional files may also be present on…
The Industrial Communication Toolbox Add-On for MATLAB and Simulink (formerly OPC Toolbox) allows communicating with an OPC UA server directly from MATLAB. This page explains…
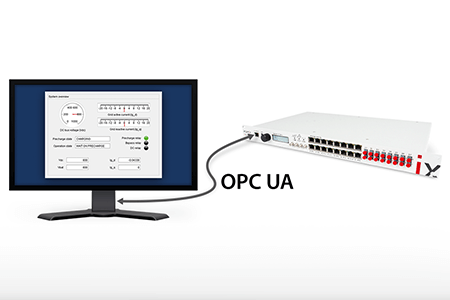
Imperix relies on the OPC UA industrial protocol to interact with programmable controllers remotely. To do so, imperix controllers (or the TPI8032) embed an OPC…
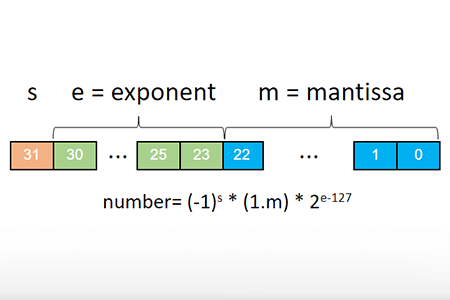
The choice of fixed vs floating-point arithmetic for an FPGA algorithm is a decision that has a significant impact on the FPGA resources usage, computation…
This page provides step-by-step guidance to install Xilinx Vivado Design Suite, the tools used to program the FPGA of imperix controllers.
End of content
End of content